MINDS CDT doctoral researcher | University of Southampton | MINDS CDT, 2022
Helping robots navigate without GPS on low-power hardware
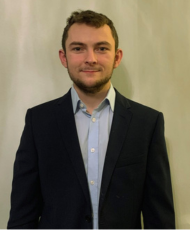
Oliver Grainge is a MINDS postgraduate researcher working on visual localisation for robots and drones: helping a robot work out where it is using only a camera, in places where GPS is unavailable or unreliable. His research makes these visual AI systems small and efficient enough to run on the low-power computers that mobile robots carry.
Research at a glance
| Research focus | Efficient visual place recognition for robots and drones |
| MINDS theme | Embedded Artificial Intelligence |
| Technologies | Computer vision, visual place recognition, neural network quantisation and pruning, compact transformer models |
| Wider applications | Robot and drone navigation where GPS is unavailable or unreliable |
| Supervisors | Dr Shoaib Ehsan and Dr Indu Bodala |
| MINDS cohort | 2022 |
Knowing where you are without GPS
Autonomous robots and drones need to know where they are to operate safely and effectively. GPS is not always available: signals can be blocked, unreliable or unsuitable in some environments. One alternative is visual place recognition, where a robot compares what its camera sees with images of places it has seen before and recognises its location.
Finding the right algorithm is only part of the challenge. The most accurate visual place recognition systems are computationally expensive, so they cannot run in real time on the limited processors that small autonomous vehicles carry.
Oliver’s research develops techniques to compress these AI systems significantly, reducing their memory footprint and computational demands while preserving their ability to recognise locations reliably. His work covers quantisation, structured pruning and compact neural network architectures, all evaluated on real-world visual place recognition benchmarks.
Why efficient visual localisation matters
Navigation where GPS falls short
Reliable camera-based localisation could help robots and drones keep track of their position in places where GPS signals are weak, blocked or unavailable.
Computing on board
Smaller, faster models may make it practical to run place recognition on the robot itself, reducing reliance on large external computing infrastructure.
Lighter, lower-power platforms
Reducing memory and processing demands has the potential to support capable visual navigation on small, battery-powered robots and drones.
Potential uses for this kind of technology include autonomous navigation, disaster response, delivery and exploration. Oliver’s work focuses on the underlying methods and their evaluation on research benchmarks.
Research approach
Oliver’s research looks at how to make visual place recognition models smaller and faster without losing the recognition performance that makes them useful. He measures recognition accuracy alongside memory use and speed, since all three matter when a model has to run on embedded hardware.
- Low-bit quantisation. Neural networks normally store their internal numbers at high precision. Quantisation stores them using far fewer bits, which shrinks the model and speeds up computation. Oliver has studied how low-bit quantisation and compact model design affect accuracy, memory and speed.
- Structured pruning. Pruning removes parts of a neural network that contribute little to its results. Structured pruning removes whole groups of components, which makes the smaller model faster to run on ordinary hardware.
- Compact transformer approaches. Transformers are a powerful type of AI model. Oliver’s TeTRA-VPR work uses a ternary approach, where values are restricted to three levels, to build a compact transformer for visual place recognition.
- Resource-constrained evaluation. Methods are tested on real-world visual place recognition benchmarks, measuring how well locations are recognised as well as memory consumption and latency.
Improving the training data
More recently, Oliver has been working on the quality of the data these systems are trained on. He is building an automated pipeline that creates high-quality training datasets from GPS-tagged images without manual labelling. Improving the training data can be as effective as improving the model itself.
Research and outputs
Oliver’s work has been published in IEEE Robotics and Automation Letters. These papers trace the development of his research from quantisation, through pruning, to compact transformer models.
Design Space Exploration of Low-Bit Quantized Neural Networks for Visual Place Recognition
Oliver Grainge, Michael Milford, Indu Bodala, Sarvapali D. Ramchurn and Shoaib Ehsan. IEEE Robotics and Automation Letters, 9(6), 2024. Read the low-bit quantisation paper (DOI: 10.1109/LRA.2024.3386459)
Structured Pruning for Efficient Visual Place Recognition
Oliver Grainge, Michael Milford, Indu Bodala, Sarvapali D. Ramchurn and Shoaib Ehsan. IEEE Robotics and Automation Letters, 10(2), 2025. Read the structured pruning paper (DOI: 10.1109/LRA.2024.3523222)
TeTRA-VPR: A Ternary Transformer Approach for Compact Visual Place Recognition
Oliver Grainge, Michael J. Milford, Indu Bodala, Sarvapali D. Ramchurn and Shoaib Ehsan. IEEE Robotics and Automation Letters, 10(8), 2025. Read the TeTRA-VPR paper (DOI: 10.1109/LRA.2025.3585715)
Research profiles
Connect with Oliver
After his PhD, Oliver plans to work as a computer vision researcher in industry. He is due to graduate in 2026.
To explore Oliver’s research or discuss potential collaboration, visit his research website or GitHub. For general enquiries about MINDS research, contact the MINDS team at mindscdt@soton.ac.uk.