MINDS CDT doctoral researcher | 2022 cohort | Due to graduate in 2026
Helping people communicate with and control robot swarms
Formal project title: Intelligent Coordination and Planning for Human-Robot Swarms
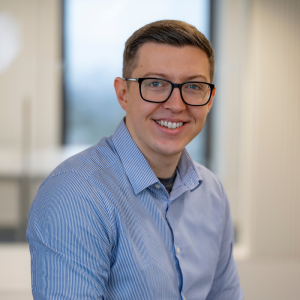
William Hunt is developing interfaces and language-based control methods that help a single human operator understand, communicate with and oversee swarms of autonomous robots.
Profiles: Research website | LinkedIn | Google Scholar | ORCID
Research at a glance
| Research focus | Human-swarm interaction |
|---|---|
| MINDS theme | Agent-Based Adaptive Systems |
| Methods and technologies | Interface design and evaluation, user studies, large language models, predictive formal modelling |
| Motivating applications | Environmental monitoring and search and rescue |
| Recognition | Best Demonstration Award, AAMAS 2023 |
| Current status | Doctoral researcher, due to graduate in 2026 |
Keeping people in control of many robots at once
Groups of autonomous robots, known as swarms, could support tasks such as environmental monitoring or search and rescue. Running many robots at once creates a difficult problem for the person in charge. They need to understand what individual robots and the wider swarm are doing, spot emerging problems and give instructions, without becoming overloaded.
Too much information can raise an operator’s workload and make the swarm hard to manage. Too little can weaken their situational awareness and make the system harder to understand or trust.
William investigates how information should be presented to someone controlling or overseeing a robot swarm. He develops and evaluates interfaces and control methods intended to help operators follow swarm behaviour and intervene effectively. His work also explores language-based interaction, including whether large language models can help people communicate with multiple robots more naturally and respond to changing situations.
Why human-swarm interaction matters
Meaningful human oversight
More effective interfaces could help people stay meaningfully in charge of autonomous systems, including when many robots are working at once.
Manageable workload
Presenting the right information at the right time could reduce unnecessary operator workload while preserving situational awareness.
Understandable swarms
Clearer communication between people and robots may support safer and more understandable operation of swarms in complex environments.
William’s work to date takes place in research demonstrations and controlled user studies. The application areas above motivate the research and do not describe systems in operational use.
Research approach
- Human-swarm teaming: studying how operators and swarms perform when working together on shared tasks.
- Predictive modelling at runtime: with collaborators, testing whether formal models that run alongside a swarm and predict likely outcomes can improve an operator’s situational awareness and performance.
- Operator workload: examining how workload changes as conditions vary, including changes in swarm size, and contributing to early work using functional near-infrared spectroscopy (fNIRS), a non-invasive brain-imaging method, to measure workload.
Research keywords: Human-swarm interaction, multi-robot coordination, human-in-the-loop control, situational awareness, operator workload, large language models
Language-based human-swarm interaction
A growing strand of William’s research looks at language as a way for people and robots to coordinate. This includes using conversational language models so an operator can coordinate several robots through dialogue, surveying how language-based communication is used across robotics, and exploring how robots negotiating with each other in natural language could guide how they learn to cooperate.
Demonstrations and recognition
William’s demonstration Demonstrating performance benefits of human-swarm teaming, developed with Jack Ryan, Ayodeji Abioye, Sarvapali Ramchurn and Mohammad Soorati, received the Best Demonstration Award at AAMAS 2023, the International Conference on Autonomous Agents and Multiagent Systems.
Selected research outputs
Journal article (peer reviewed)
- Abioye, A. O., Hunt, W., et al. (2025). A user study evaluation of predictive formal modelling at runtime in human-swarm interaction. ACM Transactions on Human-Robot Interaction, 14(4).
Conference papers (peer reviewed)
- Gu, Y., Hunt, W., et al. (2023). Successful swarms: operator situational awareness with modelling and verification at runtime. IEEE RO-MAN 2023.
- Hunt, W., Landowska, A., Maior, H., Ramchurn, S. and Soorati, M. (2026). Effects of swarm size variability on operator workload. Human Factors in Robots, Drones and Unmanned Systems, AHFE International.
Demonstration papers
- Hunt, W., Ryan, J., Abioye, A. O., Ramchurn, S. D. and Soorati, M. D. (2023). Demonstrating performance benefits of human-swarm teaming. AAMAS 2023. Best Demonstration Award.
- Hunt, W., Godfrey, T. and Soorati, M. (2024). Conversational language models for human-in-the-loop multi-robot coordination. AAMAS 2024.
Preprints (not yet peer reviewed)
- Hunt, W., Ramchurn, S. D. and Soorati, M. D. (2024). A survey of language-based communication in robotics. arXiv preprint.
- Godfrey, T., Hunt, W. and Soorati, M. D. (2024). MARLIN: multi-agent reinforcement learning guided by language-based inter-robot negotiation. arXiv preprint.
Research profiles
- William Hunt on Google Scholar
- William Hunt on ORCID
- William Hunt’s research website
- William Hunt on LinkedIn
Related stories
- From desktop AI to magnetic surgical robots: MINDS researchers at the 2026 Showcase: William’s human-swarm interaction research features in our story from the MINDS and SustAI CDT Showcase on 24 June 2026.
- Watch the MINDS and SustAI CDT Showcase 2026 highlight film, which features William and his research (YouTube).
Connect with William
Interested in human-swarm interaction, multi-robot coordination or language-based control of robots? Explore William’s research or connect with him through his professional profiles.
For enquiries about MINDS research, contact mindscdt@soton.ac.uk.